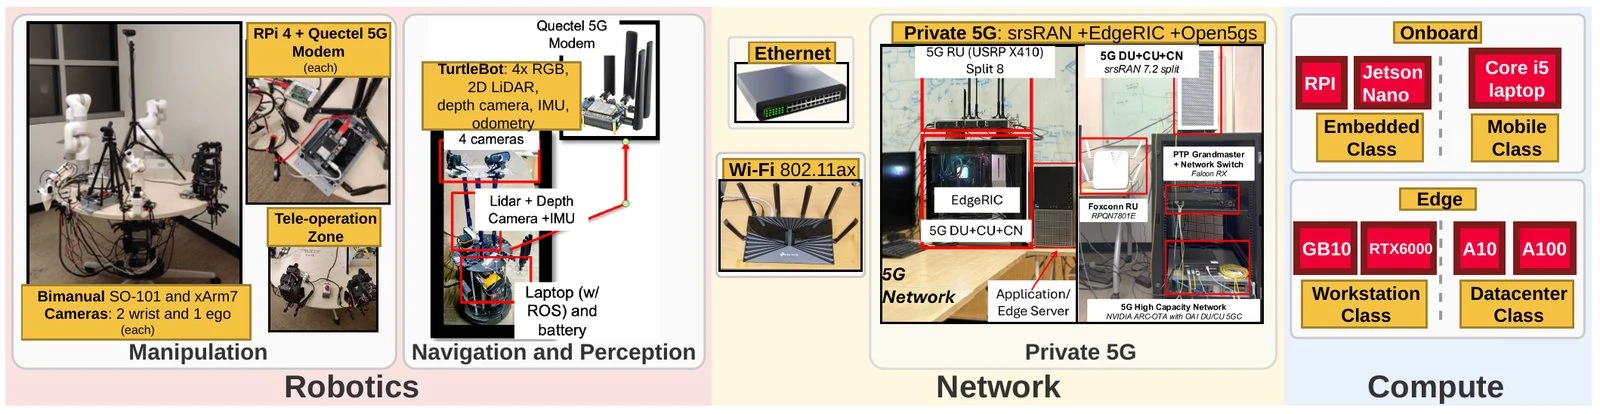
RoboNEST is an end-to-end testbed that brings real robots, interchangeable access networks, and edge GPUs into one instrumented platform, making the complete sensing-to-action path of a Physical AI task observable and controllable. Two xArm7 arms, SO-101 leader-follower arms, and a TurtleBot stream camera, LiDAR, depth, and IMU data to the edge over Ethernet, Wi-Fi 6, or a private 5G network running EdgeRIC. Vision-language-action (VLA) policies run there on GPUs ranging from A10s to an RTX 6000 and a GB10. Clock-synchronized logging correlates application events with RAN state, modem diagnostics, and GPU inference. On a 1080p manipulation task over 5G, moving the policy from an A10 to an RTX 6000 reduces glass-to-action latency from 179 ms to 111 ms; on the same GPU, Wi-Fi and Ethernet reach 77 ms and 68 ms.
@inproceedings{kadaveru2026robonest,
  author    = {Kadaveru, Sreevatsank and Ghosh, Ushasi and Bharadia, Dinesh},
  title     = {Demo: {RoboNEST}: Robotics Networked Edge Systems Testbed for Physical {AI}},
  booktitle = {Proceedings of the 32nd Annual International Conference on Mobile Computing and Networking},
  series    = {MobiCom '26},
  pages     = {1900--1902},
  year      = {2026},
  publisher = {ACM},
  doi       = {10.1145/3795866.3848480}
}