P2SIF: Plug-n-Play Sensor Integration Framework
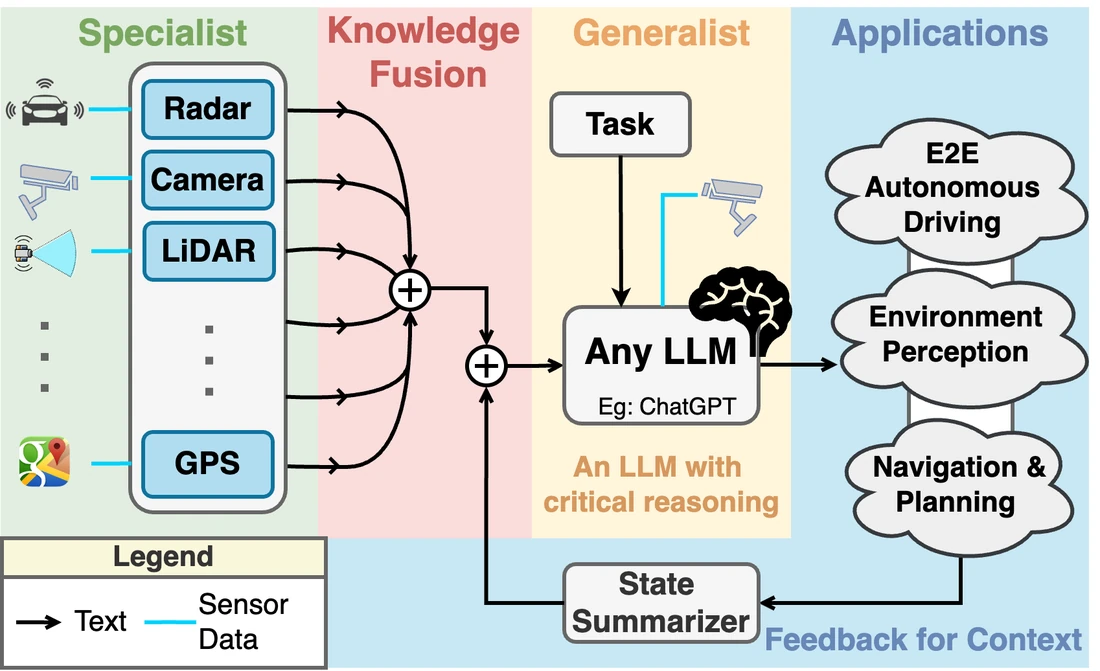
General-purpose LLMs reason effectively but cannot interpret raw LiDAR or radar data; in our tests, frontier models reported vehicles in scenes that contained none. Fine-tuning and adapter layers address this only by tying each sensor to one model’s weights. P2SIF is a decoupled architecture that integrates new modalities into existing LLMs without modifying their weights. Specialist models convert each sensor stream (camera, LiDAR, radar, GPS) into concise text reports, a knowledge-fusion stage merges them, and an unmodified generalist LLM makes the decision. New sensors can be added without retraining, the LLM can be replaced independently, and each decision leaves a human-readable trail for failure attribution. The target applications are autonomous-driving tasks in CARLA and on real LiDAR, radar, and camera data, including fog and night driving.